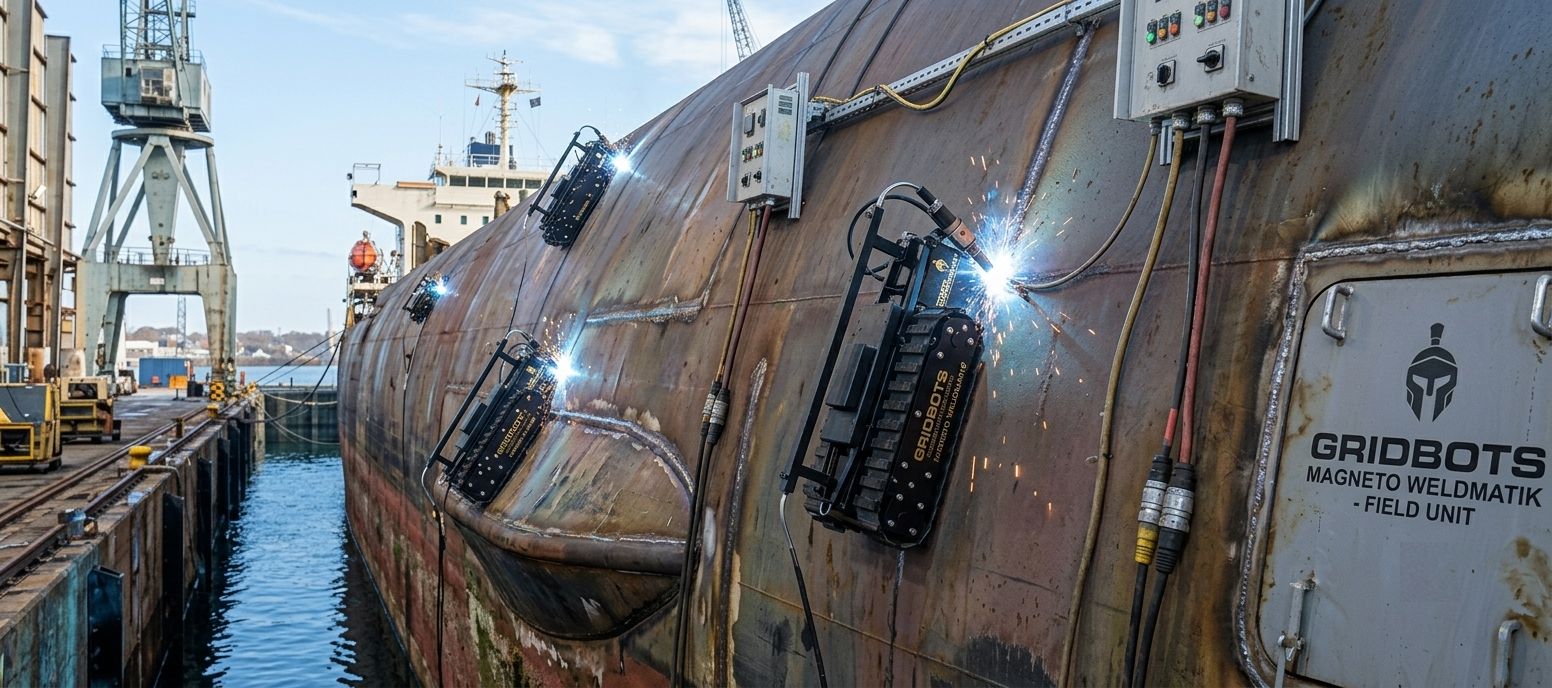
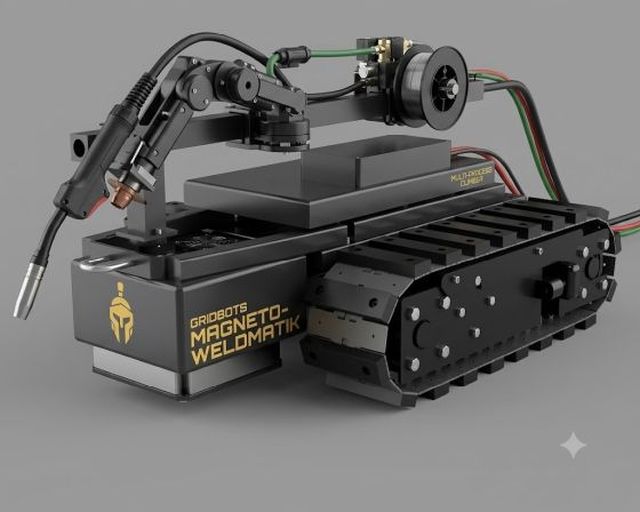
Gridbots Magneto-WeldMATIK is a rugged, wall-climbing welding robot that uses high-strength magnetic tracks to climb vertical, inclined and curved steel surfaces and lay consistent, high-integrity MIG/MAG (GMAW) welds – without scaffolding, cranes or rope access.
It is built for long vertical and horizontal seams on storage tanks, ship hulls, wind tower sections, penstocks, pressure vessels, boiler waterwalls and large structural fabrications – places where manual welding is slow, fatiguing and inconsistent.
An array of rare-earth NdFeB magnets in the tracks gives up to 250 kg of adhesion, while closed-loop travel control, a programmable torch oscillator and laser seam tracking hold the torch exactly on the joint throughout the pass.
A dedicated weld camera with HDR arc-view and three FHD navigation cameras stream live video to the operator, who controls travel speed, oscillation, wire feed and arc parameters from a safe distance.
The robot works with standard industrial MIG power sources (350A / 500A class) and wire feeders, making it easy to integrate into existing welding setups and qualified WPS.
* Typical values from long-seam field welding compared with manual welding. Actual results depend on joint, position and WPS.
The WeldMATIK controller combines crawler motion and welding control in one rugged, IP-rated console with an HDMI touch display. The operator sets travel speed, oscillation width, frequency and side-wall dwell, and adjusts wire feed speed and voltage trim live while watching the arc on screen.
Weld programs can be stored and recalled per WPS, and every pass is logged with current, voltage, travel speed and heat input against seam position – giving QA teams a traceable weld record for each joint.
A handheld wireless pendant allows fine jogging and torch alignment near the joint, and dual E-stops stop motion and arc instantly.
Live HDR weld-camera view of the arc and molten pool as seen by the operator
Magnetic tracks climb vertical, inclined & overhead steel surfaces
MIG / MAG (GMAW) – short-circuit, pulse & spray transfer
Laser seam tracking with automatic torch correction (±0.2 mm)
Programmable torch oscillation – width, frequency & side dwell
Navigates convex & concave surfaces down to 1.5 m diameter
Adhesion Force 250 kg with NdFeB magnet array
Stepless travel speed 50 – 1200 mm/min with closed-loop control
HDR weld camera + 3 FHD cameras for live arc & bead inspection
Weld data logging – current, voltage, speed & heat input per seam
Works with standard 350A / 500A MIG power sources & feeders
Constant travel speed, fixed torch angle and real-time seam tracking remove the main sources of variation in manual vertical welding. The result is uniform bead profile, full sidewall fusion and dramatically fewer repairs – verified by visual, radiographic and mechanical testing.
Uniform ripple pattern on a 3G vertical-up cap pass
Etched macro section showing full fusion & sound root
Radiograph free of porosity & lack of fusion
Single-V butt joint, 12 mm carbon steel, 3G vertical-up, 3 passes
ER70S-6, 1.2 mm wire, Ar + 18% CO₂, 3G vertical-up
| Pass | Current (A) | Voltage (V) | Travel (mm/min) | Weave (mm) |
|---|---|---|---|---|
| Root | 130 – 150 | 17 – 18 | 90 – 120 | 0 – 3 |
| Fill | 160 – 190 | 19 – 21 | 70 – 100 | 6 – 12 |
| Cap | 150 – 175 | 18 – 20 | 60 – 90 | 12 – 18 |
Indicative starting values only. Final parameters are set per the qualified WPS.
Bead width measured every 100 mm along a 1 m vertical seam
Percentage of weld length requiring repair, by defect type
Vertical seam, 12 mm plate, single operator
Wire feed speed vs. welding current, 1.2 mm ER70S-6
| Test | Standard | Typical Result | Status |
|---|---|---|---|
| Visual Inspection | ISO 5817 / AWS D1.1 | No undercut > 0.5 mm, uniform reinforcement | PASS |
| Radiographic Testing (RT) | ASME Sec. V / ISO 17636 | Free of porosity, slag & lack of fusion | PASS |
| Transverse Tensile | ASME Sec. IX QW-150 | 520 MPa, failure in base metal | PASS |
| Face & Root Bend (180°) | ASME Sec. IX QW-160 | No open defects | PASS |
| Charpy V-Notch Impact | ASTM E23 @ −20°C | 85 J average (weld metal) | PASS |
| Hardness Survey | ISO 9015-1 (HV10) | HAZ max 230 HV10 | PASS |
| Macro Examination | ISO 17639 | Full fusion, sound root, no cracks | PASS |
Representative results on carbon steel test coupons. Actual results depend on base material, consumables, joint preparation and the qualified WPS/PQR.
| Parameter | Manual Welding | Magneto-WeldMATIK |
|---|---|---|
| Access | Scaffolding / man-lift / rope access | Magnetic climbing – no scaffolding |
| Arc-on time | 25 – 35% | Up to 85% |
| Bead width variation | ±1.5 mm | ±0.2 mm |
| Repair rate | 3 – 5% | < 1% |
| Welder fatigue / exposure to fumes & heights | High | Operator at safe distance |
| Weld traceability | Manual records | Automatic data log per seam |
| Skill dependence | Highly skilled certified welder | Trained operator with programmed WPS |
| Model Number | GB-MAGNETO-WELDMATIK |
| Drive | 2 Powered Magnetic Tracks |
| Magnets Used | Array of NdFeB Rare-Earth Magnets |
| Adhesion Force | Up to 250 Kg |
| Payload | Up to 40 Kg (torch, oscillator, sensors, wire feeder option) |
| Travel Speed | 50 – 1200 mm/min (stepless, closed-loop) |
| Encoder Motion Resolution | 0.1 mm Increments |
| Min. Surface Thickness | 6 mm ferromagnetic steel |
| Min. Curvature | 1.5 m diameter (convex & concave) |
| IMU | 100Hz - 6 DOF |
| Provided Umbilical Length | Up to 50 Meters (extendable) |
| Robot Weight | 32 Kgs (without wire feeder) |
| Power | 24V DC [Drive & Electronics] |
| Cameras | 1 HDR Weld Camera + 3 FHD Navigation Cameras |
| Remote Control | Tethered Controller + Wireless Pendant, Kevlar safety rope |
| Build Material | Aircraft Grade Aluminum and SS-316 |
| Welding Process | MIG / MAG (GMAW); FCAW optional |
| Metal Transfer Modes | Short-Circuit, Pulse, Spray |
| Compatible Power Source | 350A / 500A Inverter MIG (Analog / Digital Interface) |
| Torch | Water-Cooled Machine Torch, 500A @ 100% Duty Cycle |
| Wire Diameter | 0.8 / 1.0 / 1.2 mm Solid; 1.2 / 1.6 mm Flux-Cored |
| Shielding Gas | Ar + CO₂ mixes, 100% CO₂ |
| Weld Positions | 2G, 3G (Vertical Up / Down), 4G; 2F, 3F, 4F |
| Joint Types | Butt (V, X, Single Bevel), Fillet, Lap |
| Torch Oscillation | Width 0 – 30 mm, Frequency 0.5 – 3 Hz, Side Dwell 0 – 2 s |
| Seam Tracking | Laser Line Sensor, ±0.2 mm Lateral Correction |
| Torch Adjustment | Motorised Cross-Slide (Lateral & Height), Manual Angle Set |
| Weld Data Logging | Current, Voltage, Wire Feed, Travel Speed, Heat Input |
| Base Materials | Carbon Steel, Low-Alloy Steel (robot must travel on ferromagnetic surface) |
| IP Rating | 65 |
| Operating Temperature | 5°C to 55°C |
| Max. Surface Temperature | 120°C (pre-heated plates) |
| Humidity | 95%, Non-Condensing |
| TOF Sensors (Edge / Obstacle Detection) | 6x |
| Magnetic Adhesion Monitoring | Continuous, with Auto-Stop |
| Arc & Gas-Flow Fault Detection | Yes |
| Impact Sensor | 1x |
| E-Stop (Motion + Arc) | 2x |
| Fall Arrest | Kevlar Safety Rope Anchor |